I am a Research Assistant at OpenDriveLab, The University of Hong Kong, supervised by Prof. Hongyang Li.
I earned my M.Phil. in Robotics and Autonomous Systems from the Hong Kong University of Science and Technology (Guangzhou), where I worked in RIL-Lab under the supervision of Prof. Qiang Nie and was co-supervised by Prof. Renjing Xu.
My research interests focus on humanoid motion control, whole-body control, and loco-manipulation. I have recently been exploring agentic robotics.
Research Interests
News
- 2026.10PingPongDuo is released! Project page · arXiv .
- 2026.09Our paper, PingPongDuo: Agile Humanoid Table Tennis Doubles with Safe Team Coordination, has been submitted to ICRA 2027.
- 2026.07Our team won the RoboCup World Cup Soccer 3D Simulation championship.
- 2026.06Won the HKUST(GZ) Campus Top 10 Singing Competition championship.
- 2026.02Our paper on bimanual active perception was accepted by ICRA 2026.
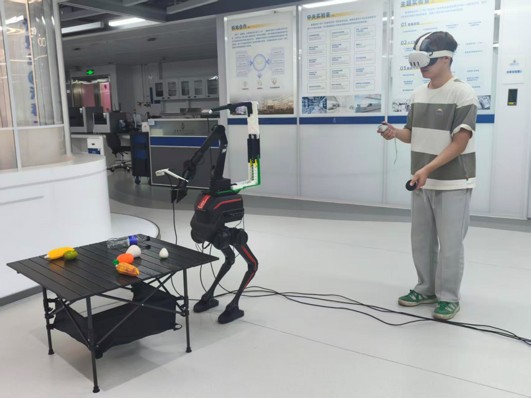
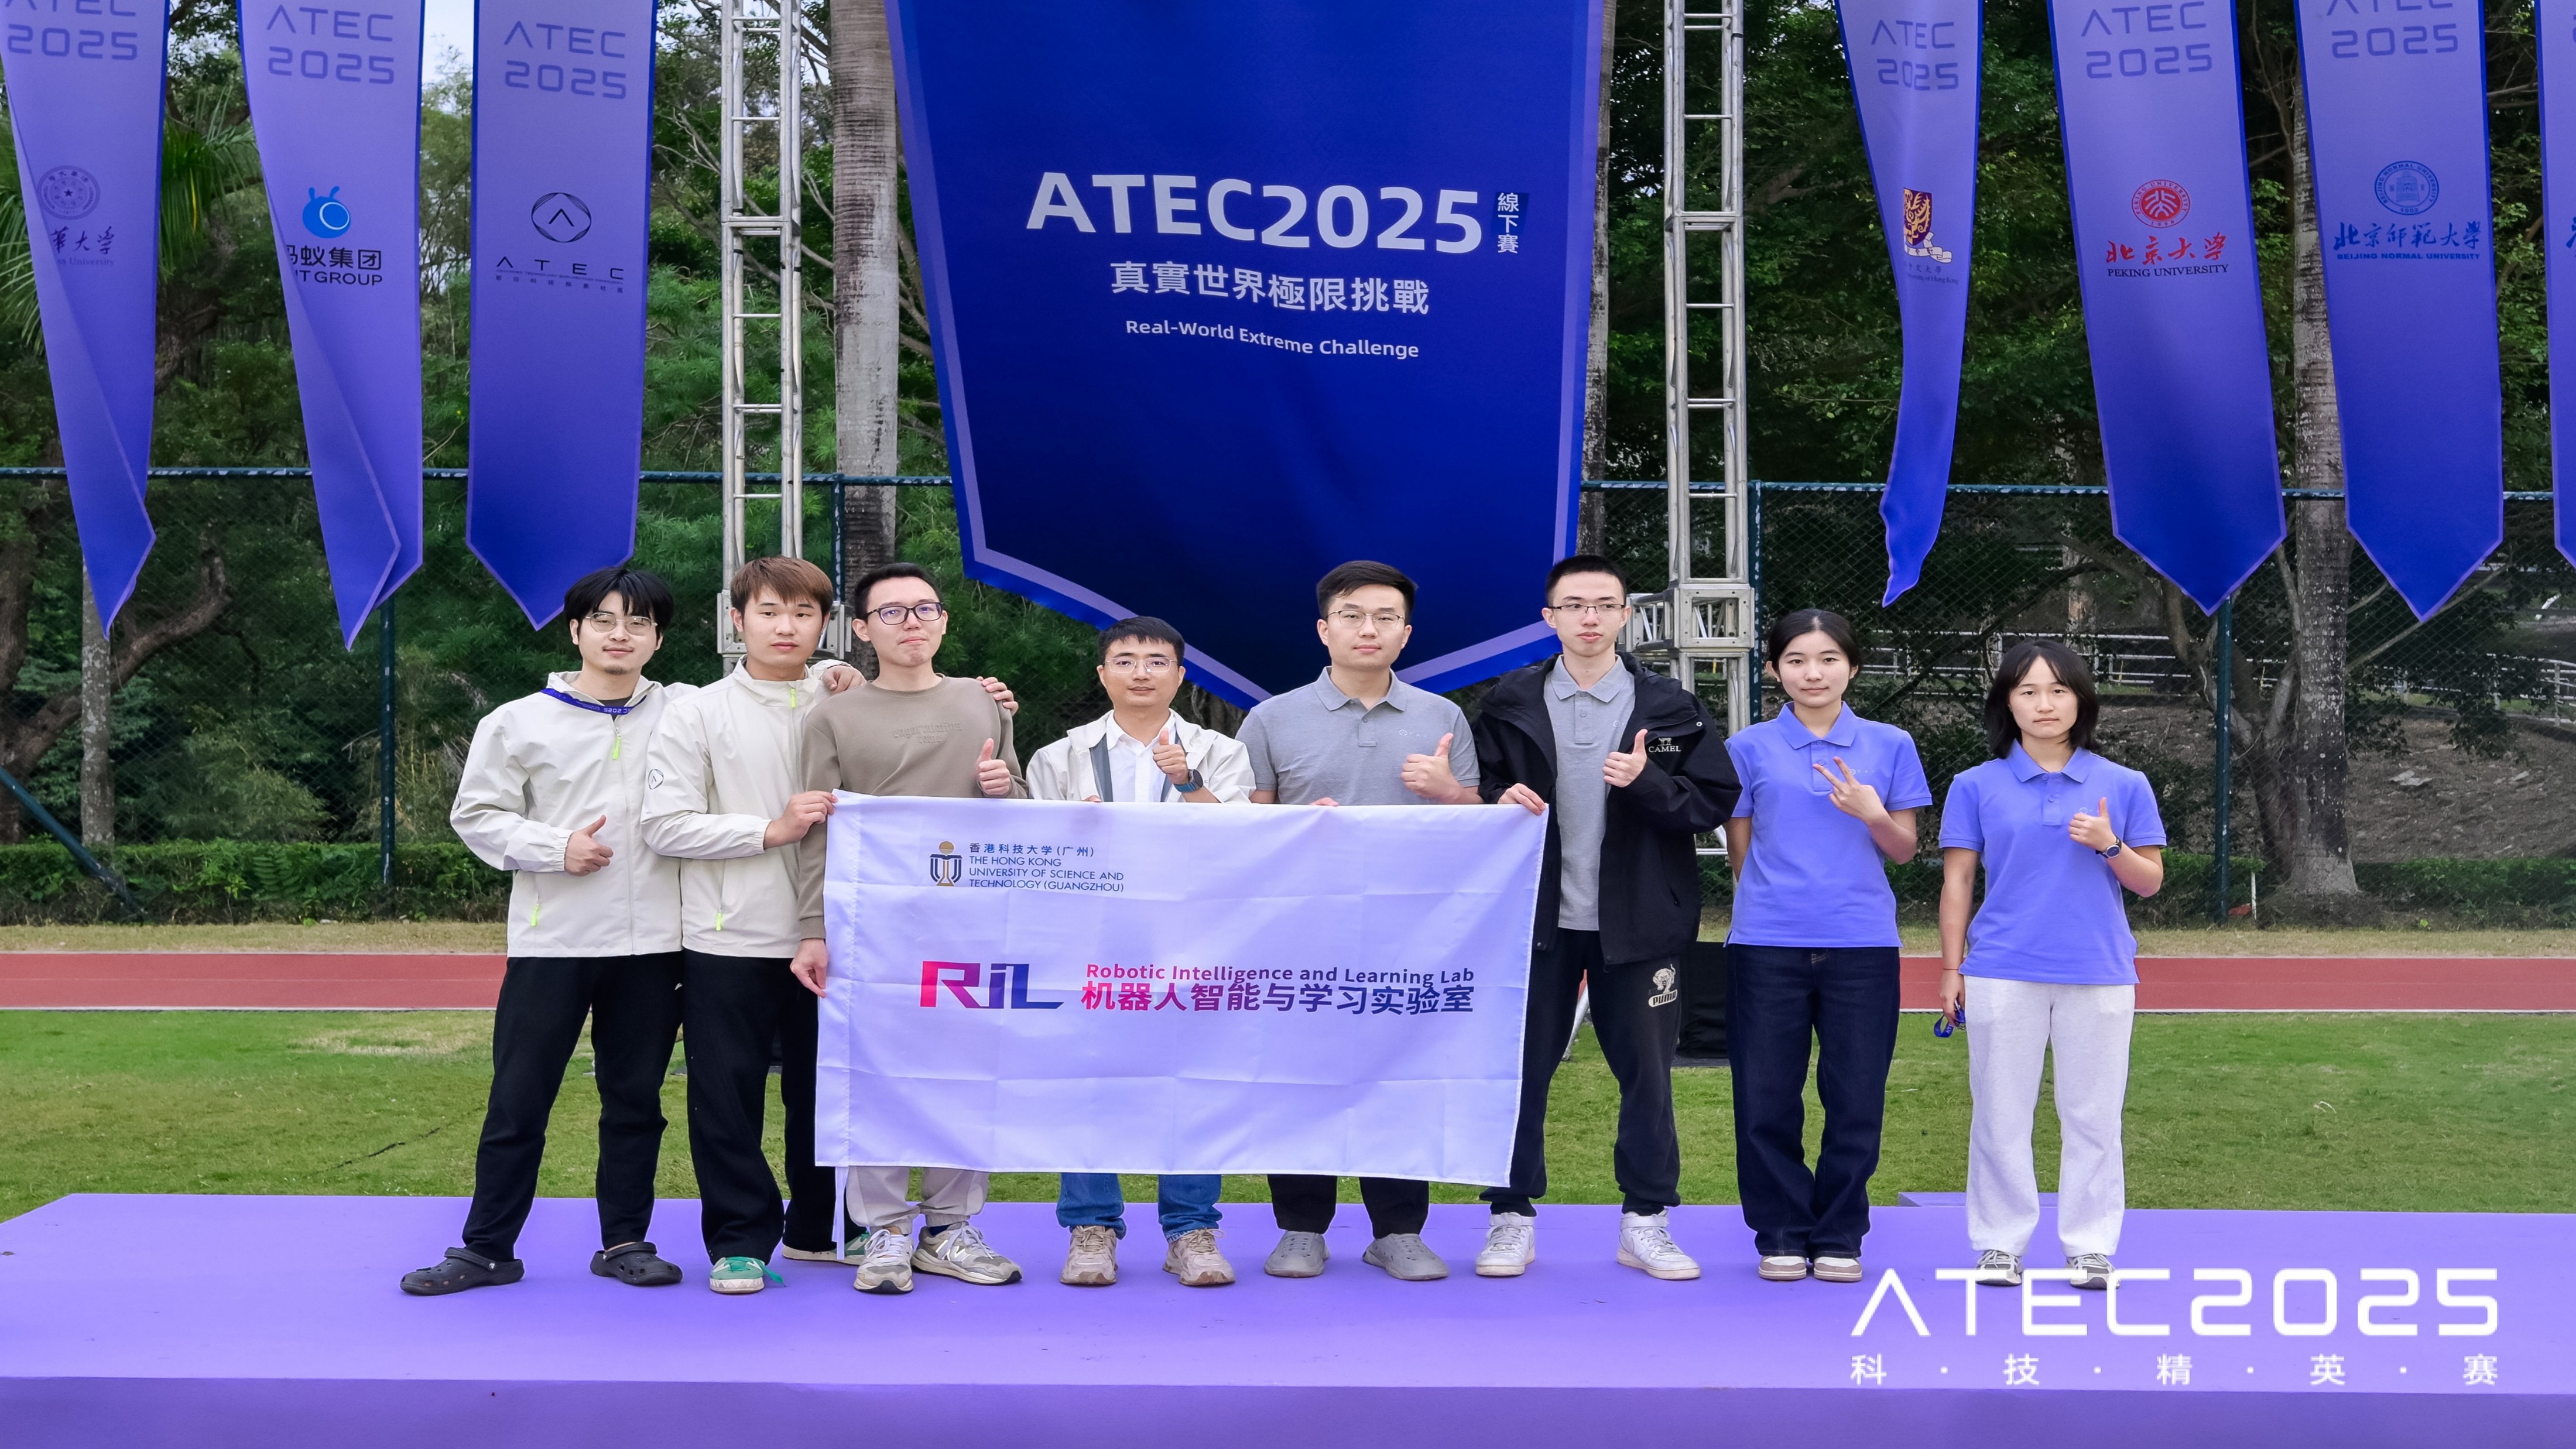
- 2025.12Led the team to 8th place in the ATEC 2025 Real-World Extreme Challenge.
- 2025.10Won 3rd place in the IROS 2025 Robot Dance Competition.
Research
PingPongDuo: Agile Humanoid Table Tennis Doubles with Safe Team Coordination
Agile humanoid table tennis doubles with safe team coordination. Contributed to the RL planner's sim-to-real integration and deployment on humanoid robots. Project page and arXiv preprint are now available.
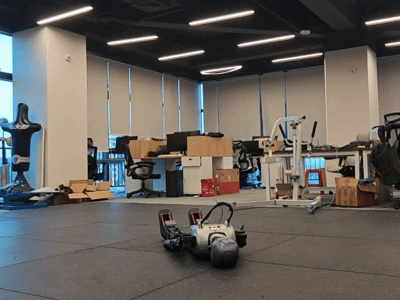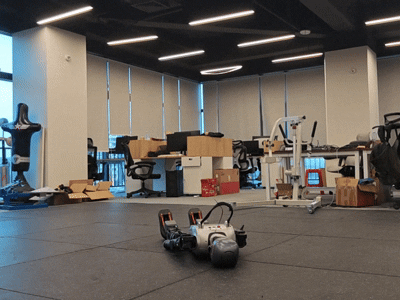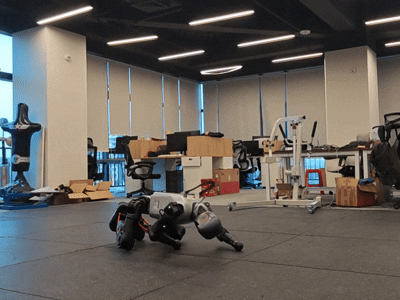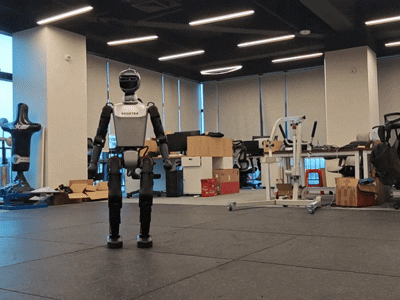
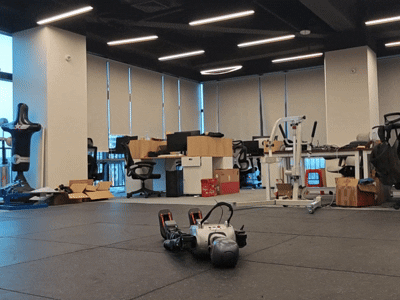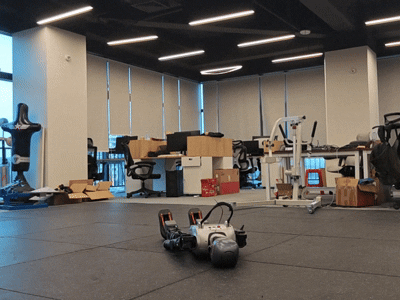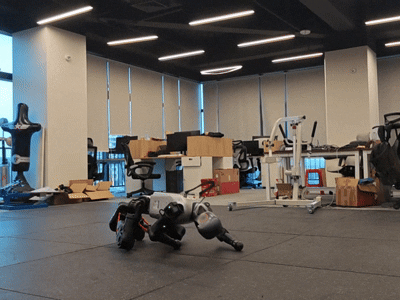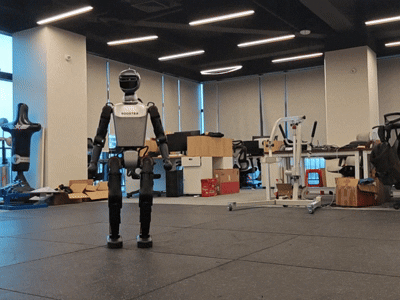
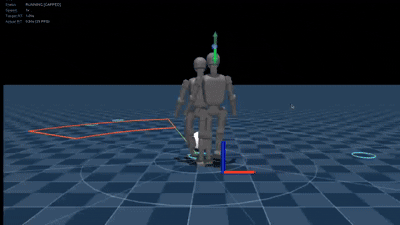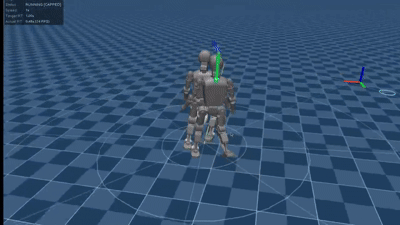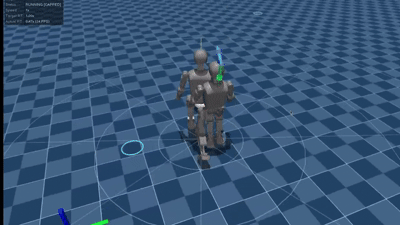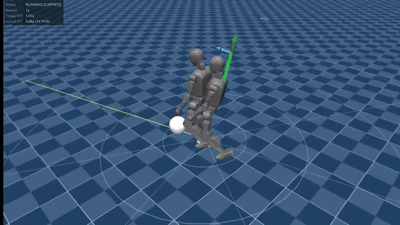
Learning Robust Humanoid Motion Control for Robot Soccer
A unified recovery-locomotion framework designed to recover from diverse falls, resume walking, and remain robust under physical variation.
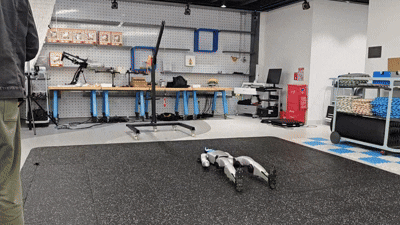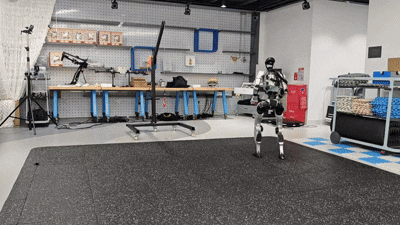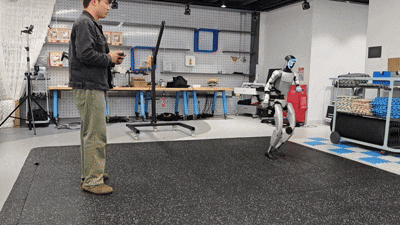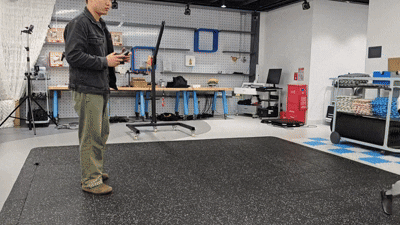
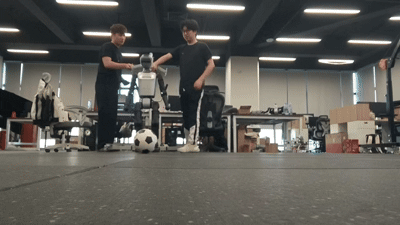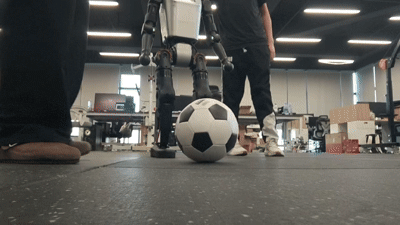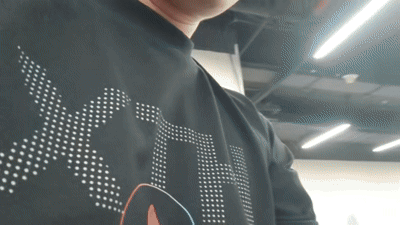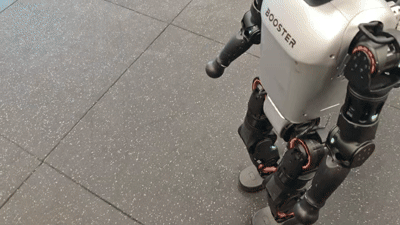
Self-Play Dribbling for Humanoid Robot Soccer
A self-play learning framework for agile dribbling policies in competitive multi-agent environments.
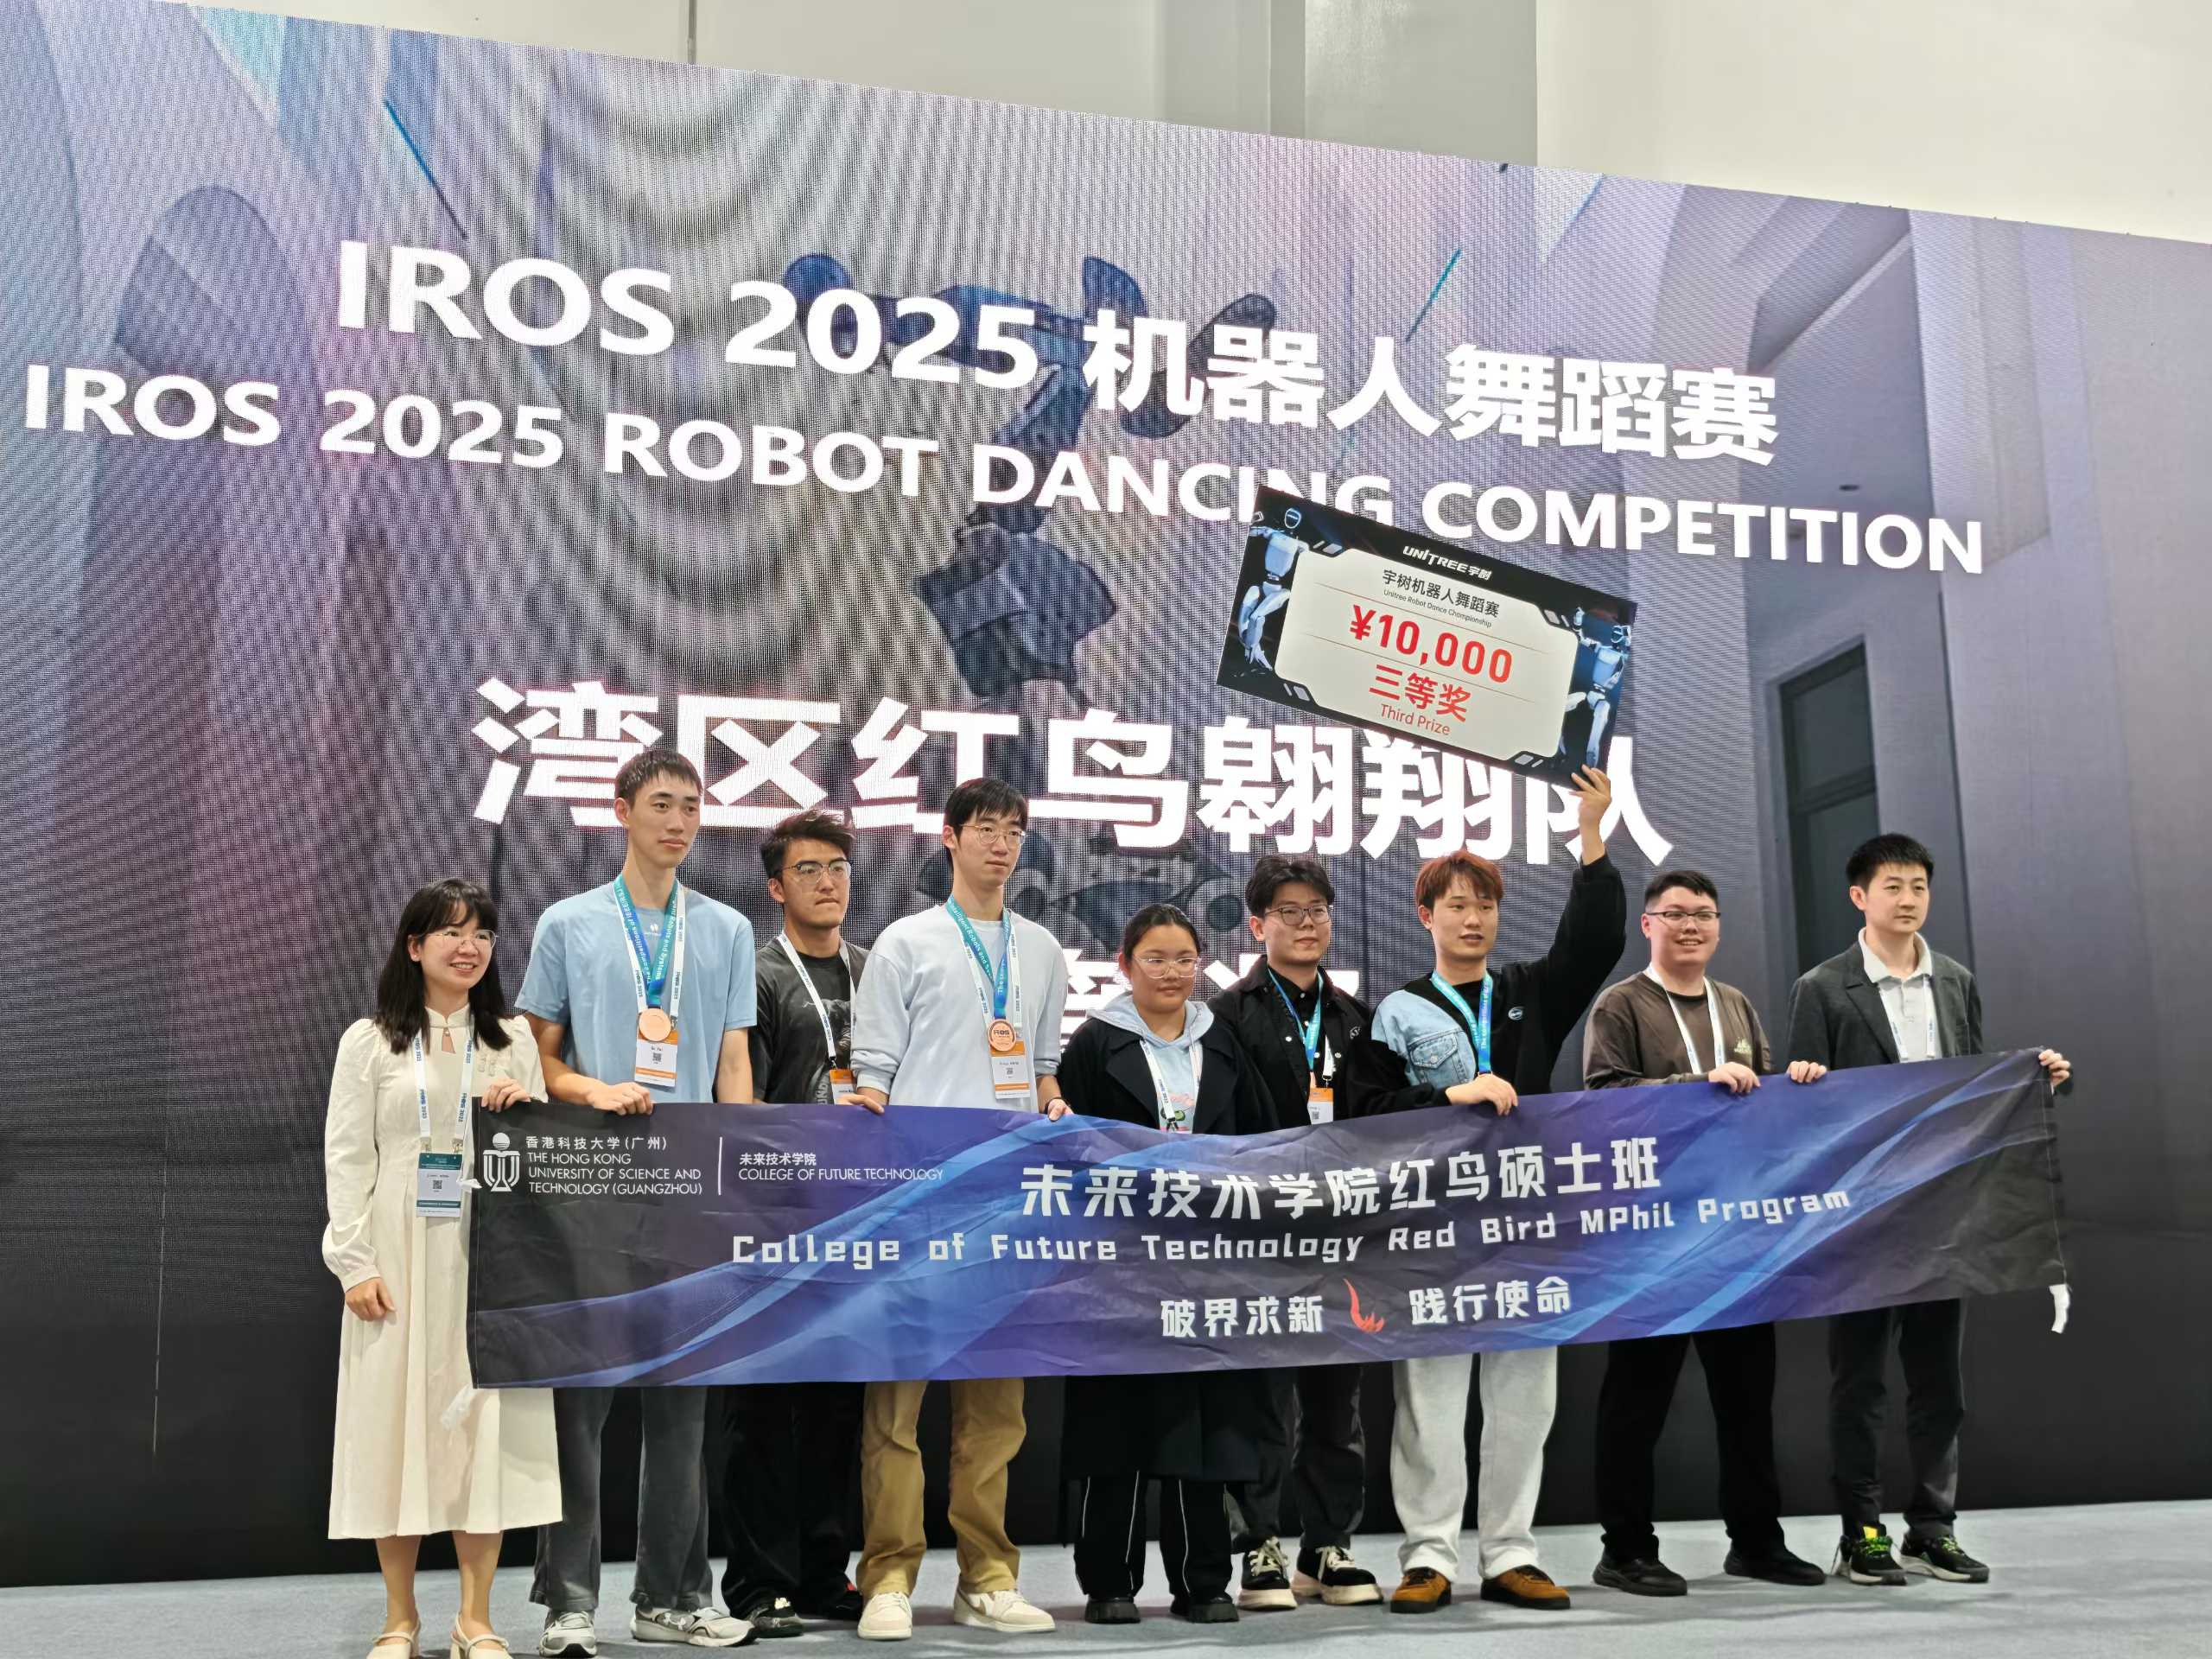
3rd prize, IROS 2025 Robot Dancing Competition
A motion-retargeting and whole-body-control pipeline for transferring human motion from video to a Unitree G1 humanoid robot.
Publications
PingpongDuo: Agile Humanoid Table Tennis Doubles with Safe Team Coordination
arXiv:2610.20579, 2026 · Submitted to ICRA 2027
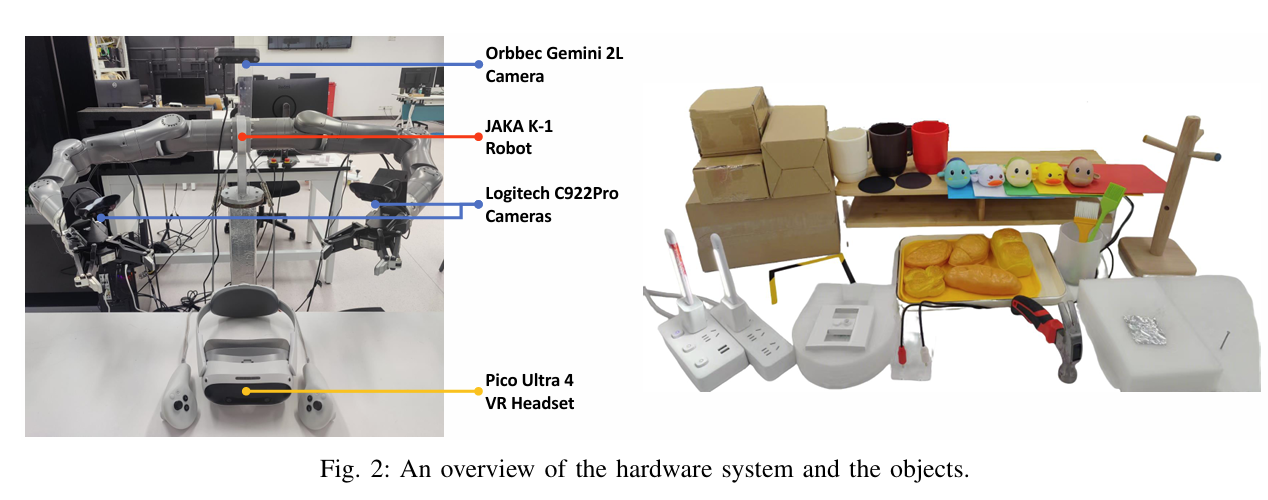
Towards Exploratory and Focused Manipulation with Bimanual Active Perception: A New Problem, Benchmark and Strategy
IEEE International Conference on Robotics and Automation (ICRA), 2026 — Accepted
Education
-
 The Hong Kong University of Science and Technology (Guangzhou) Sep. 2024 - Oct. 2026M.Phil. in Robotics and Autonomous Systems · Guangzhou, China Awarded a Full M.Phil. Scholarship.
-
 Nanjing University of Posts and Telecommunications Sep. 2020 - Jun. 2024B.Eng. in Electromagnetic Fields and Wireless Technology · Nanjing, China Awarded the National Encouragement Scholarship (Top 5%) and First-Class Academic Scholarship (Top 5%).
Intern / Working Experience
-
 OpenDriveLab, The University of Hong Kong Sep. 2026 - PresentResearch Assistant · Humanoid Robotics · Hong Kong
Contributed to PingPongDuo: Agile Humanoid Table Tennis Doubles with Safe Team Coordination (arXiv:2610.20579; submitted to ICRA 2027), leading the RL planner's sim-to-real deployment.
-
 Institute for AI Industry Research (AIR), Tsinghua University Jan. 2025 - Feb. 2025Embodied AI Winter Camp · Outstanding Camper · Beijing, China
Built a simulation data-collection pipeline and deployed ACT (Action Chunking with Transformers) for imitation learning on robotic arm manipulation tasks.
-
 MiraclePlus(奇迹创坛) 24Fall 2024Co-Founder · Beijing, China
Co-founded the team and was responsible for the mechanical design of humanoid robots.
link -
 Xbotpark Jul. 2022 - Aug. 2022Entrepreneurial Camp · Team Leader · Changzhou, Jiangsu
Developed a medical IoT prototype using STM32, RFID, and Wi-Fi to improve hospital workflows; awarded Best Project.
-
 DJI RoboMaster Feb. 2022Teaching Assistant · Internship · Shenzhen, China
Managed and maintained laboratory equipment and campus computing infrastructure for the RoboMaster summer camp.
Project & Competition Experience
-
RoboCup 3D Simulation Competition — Team Member Mar. 2026HKUST(GZ) Built a curriculum-learning fall-recovery policy with PPO, key-state initialization, and domain randomization.
-
ATEC 2025 Real-World Extreme Challenge — Team Leader / Core Developer Sep. 2025 - Dec. 2025CUHK & Alibaba Led the team to 8th place and developed teleoperation, data-collection, and bimanual locomotion components.
-
IROS 2025 Robot Dance Competition — Project Leader Jun. 2025 - Oct. 2025Guangdong, China Developed a video-to-dance pipeline for Unitree G1 using motion retargeting and whole-body control; won 3rd place.
-
RoboCup 3D Simulation Competition — Team Leader / Algorithm Developer Nov. 2020 - Nov. 2022NJUPT Implemented role assignment and collaboration algorithms and optimized bipedal walking using CMA-ES.
Projects
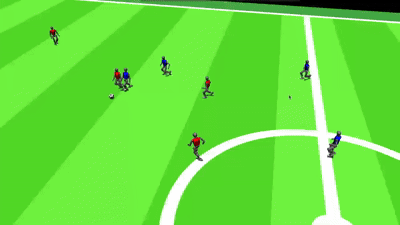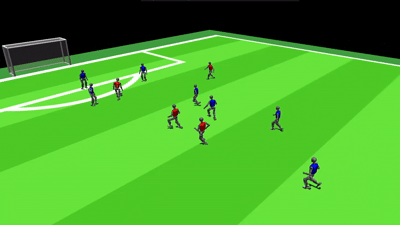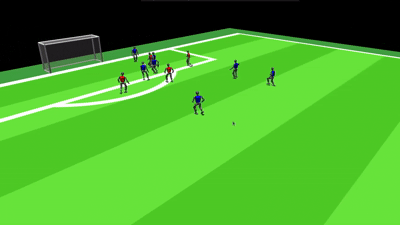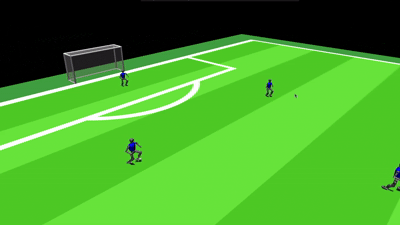
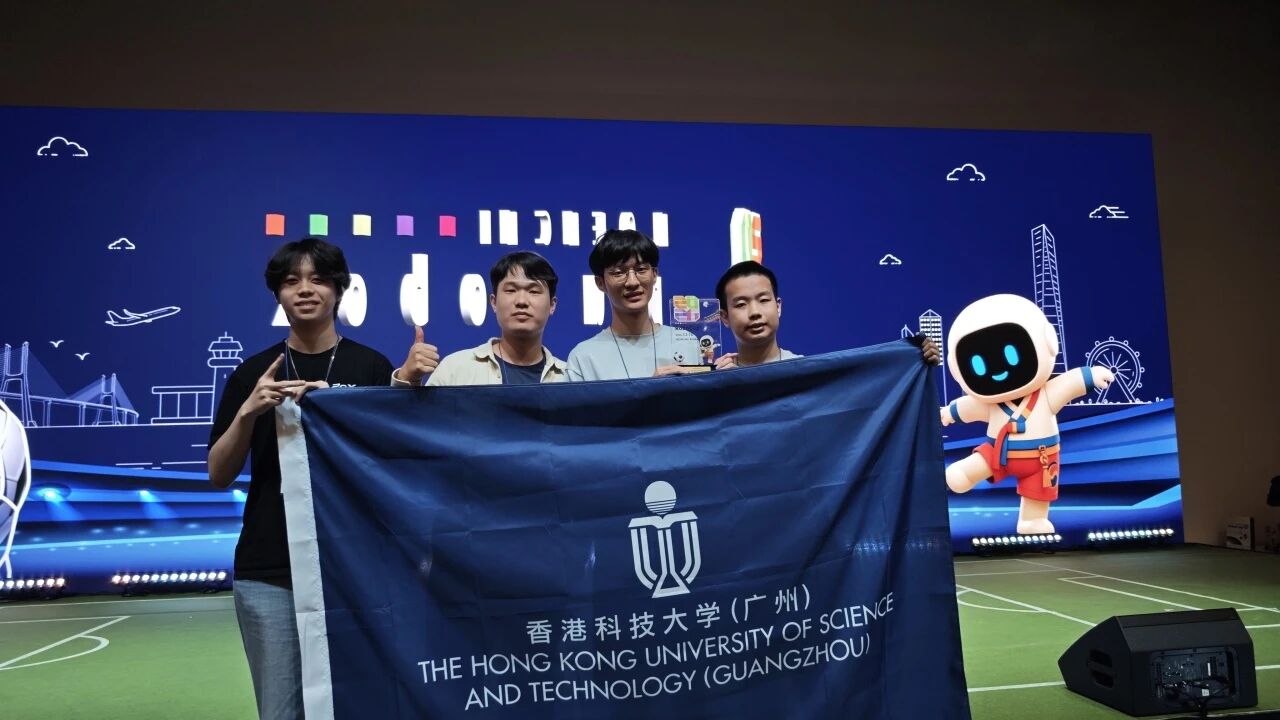
HKUST(GZ) RoboCup Team
Humanoid Robot Soccer
Role: Team Member · HKUST(GZ)
Part of the HKUST(GZ) team that won the RoboCup 2026 Soccer 3D Simulation world championship.
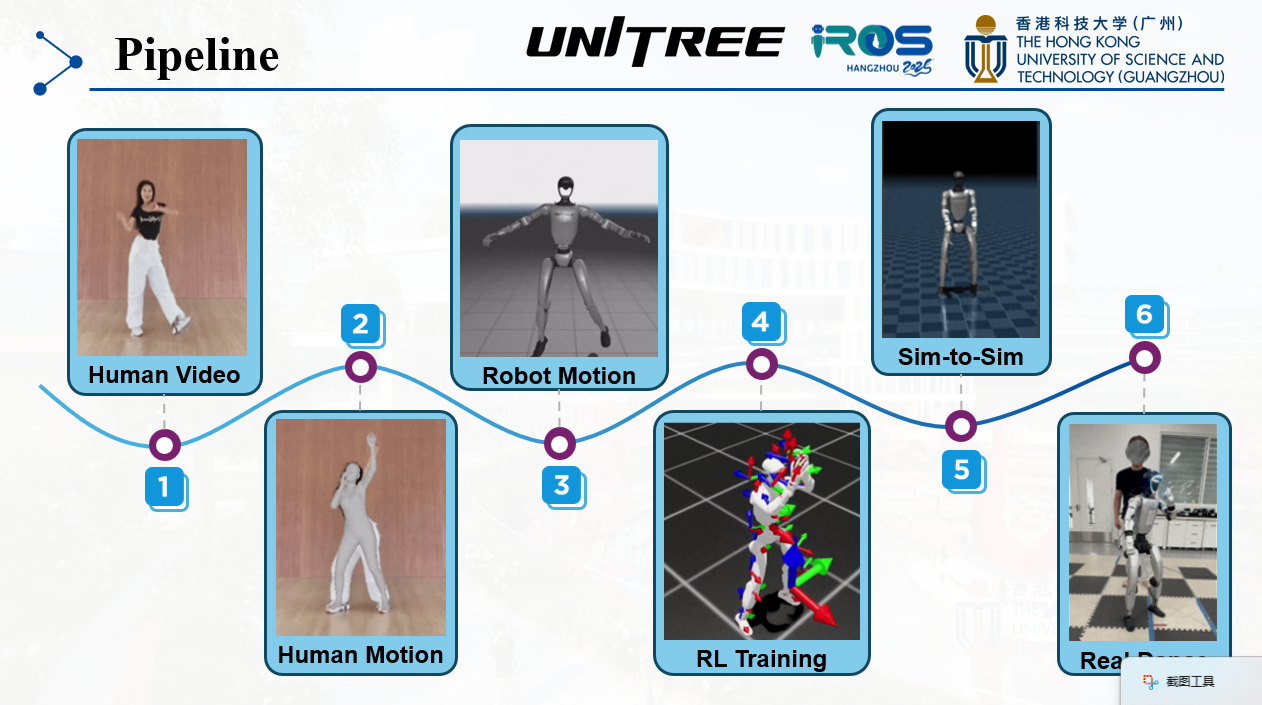
3rd prize, IROS 2025 Robot Dancing Competition
From Video to G1 Dance · Unitree G1
Role: Project Leader
3rd Prize · IROS 2025
Built a video-to-dance pipeline that transfers human motion to a Unitree G1 humanoid through motion retargeting and whole-body control.
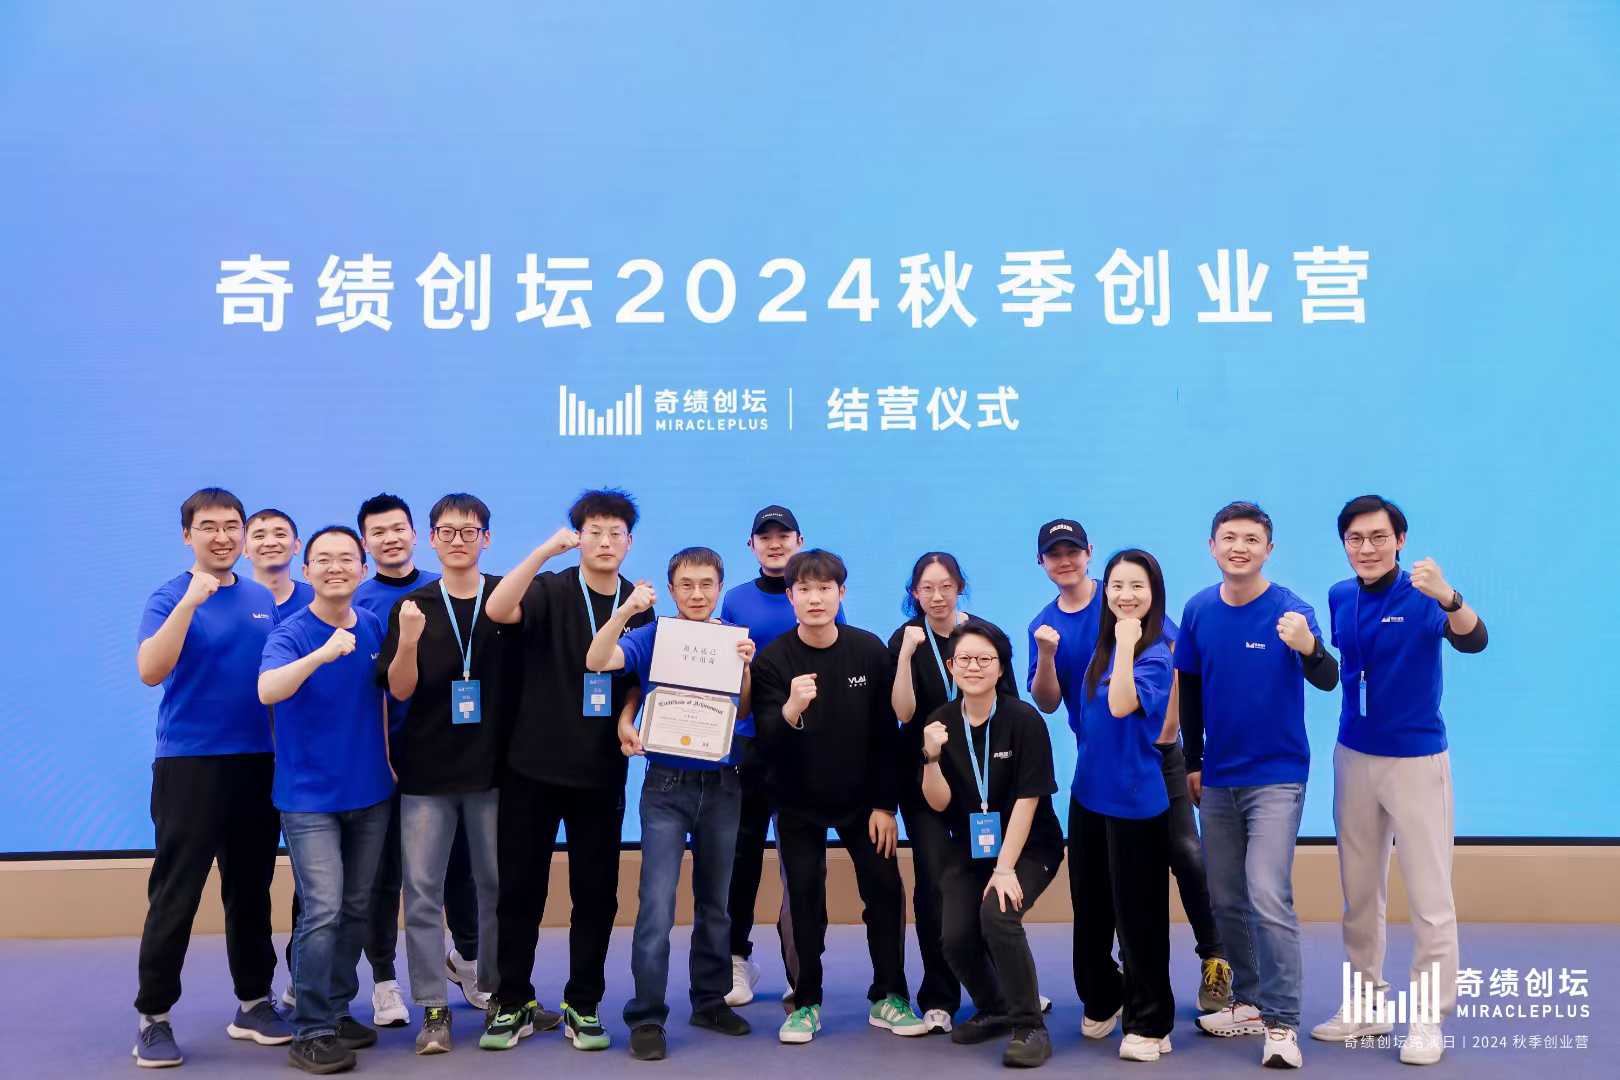
MiraclePlus(奇迹创坛) 24Fall
Fall 2024 Startup Camp · Beijing, China
Role: Co-Founder
Co-founded the team and led the mechanical design of its humanoid robots.
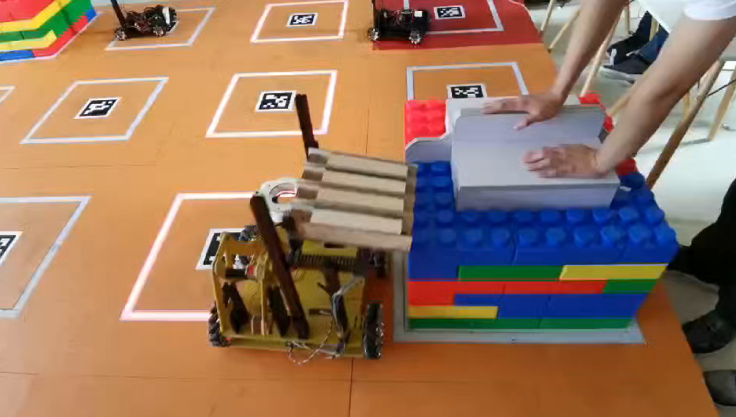
DJI RoboMaster High-School Camp
Hands-on Robot Building
Built a robot during the DJI RoboMaster high-school summer camp.
Technical Skills
Languages & Frameworks
Robotics
Tools & Hardware
Honors & Awards
- 2026: RoboCup World Cup Soccer 3D Simulation Champion
- 2026: HKUST(GZ) Campus Top 10 Singing Competition Champion
- 2025: ATEC Real-World Extreme Challenge — 8th Place
- 2025: IROS Mecha Challenge (Robot Dance) — 3rd Place
- 2024: Honor Degree and General Scholarship (Top 5%), NJUPT
- 2023: National Inspiration Scholarship
- 2022: RoboCup China Competition National Championship
- 2021: RoboCup World Cup — Third Prize
- 2019: DJI RoboMaster Robot Summer Camp — Third Prize